GraphWalker: Deployable Inertial-Based Indoor Localization via Trajectory to Graph Alignment
To appear in Proceedings of the 34th ACM International Conference on Advances in Geographic Information Systems (SIGSPATIAL), 2026
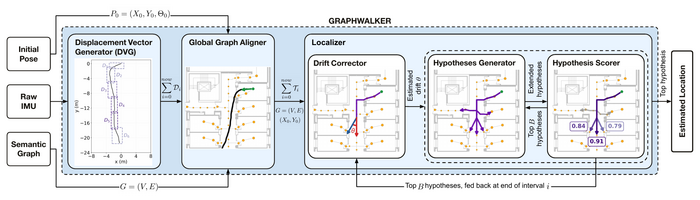
Inertial indoor localization is attractive because it requires no infrastructure and reveals no identifying signals, yet unbounded drift and the absence of a global coordinate frame prevent it from serving as a standalone solution. Existing map-constrained approaches mitigate drift using floor plans, but typically rely on dense geometric maps, calibrated probabilistic models, or offline global inference. We present GraphWalker, a real-time indoor localization system that aligns IMU-derived trajectories with coarse semantic floor plan graphs through online trajectory-to-graph alignment. GraphWalker maintains multiple candidate path hypotheses through bounded beam search and independently corrects drift for each hypothesis, requiring only a coarse semantic graph, a known starting pose, and commodity inertial sensing. On 152 real-world trajectories totaling 9 km of walking across three floor plans, GraphWalker improves localization accuracy by up to 50% over map-free and map-constrained baselines and reduces path errors by 42%, while maintaining real-time operation.