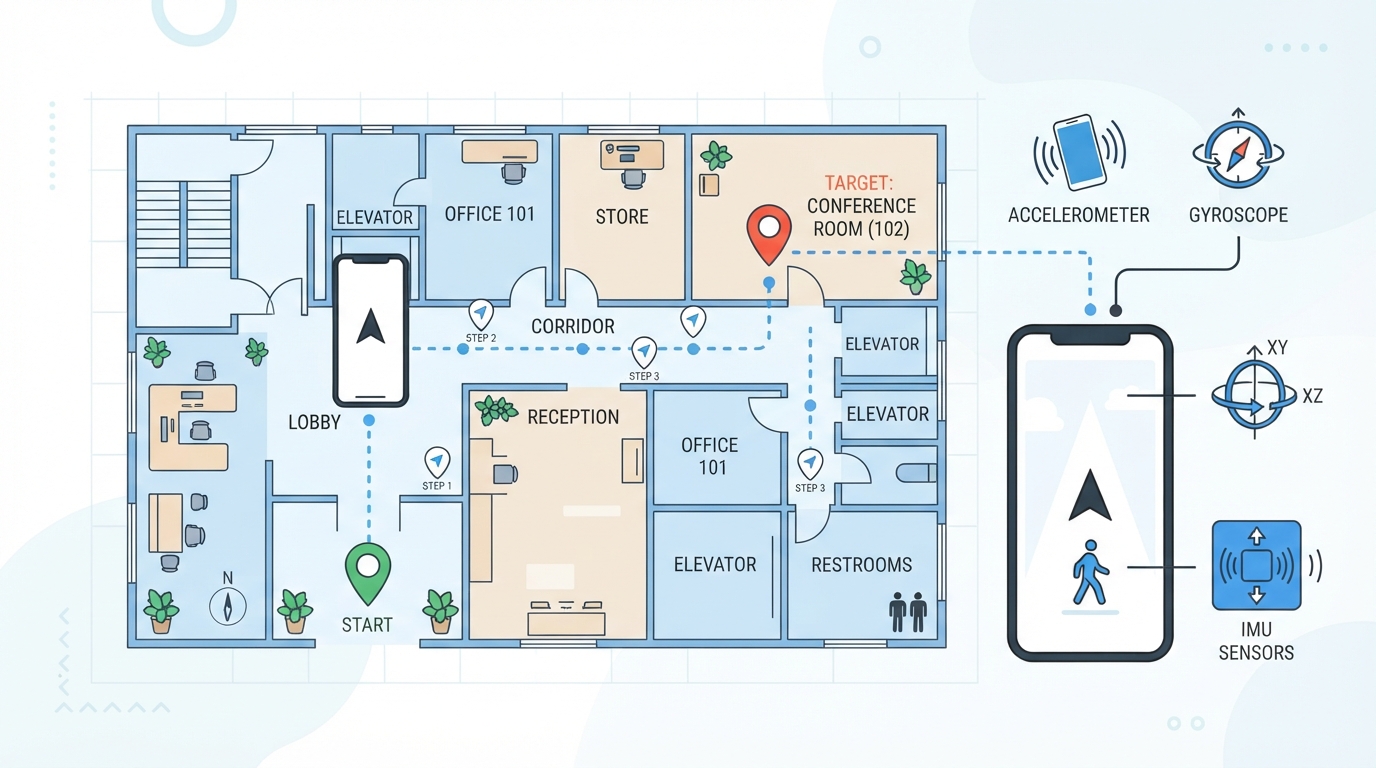
Morshed: A Personalized and Multimodal Ubiquitous Indoor Navigation System (CMU-Q Accelerator Grant)
Eduardo Feo Flushing (LPI), Khaled Harras, Mai Al-Mashhadani, Yaqoob Ansari
Morshed aims to make indoor navigation practical and widely deployable by prioritizing effective guidance over precise positioning. It combines automated floor plan encoding, coarse tracking on standard smartphones, and personalized, privacy-preserving interaction to deliver turn-by-turn navigation with minimal infrastructure. The project will produce deployable prototypes, open datasets, and open-source tools to support accessible indoor navigation and location-aware services in complex venues, contributing to Qatar’s goals for smart infrastructure and digital transformation.

Related Publications
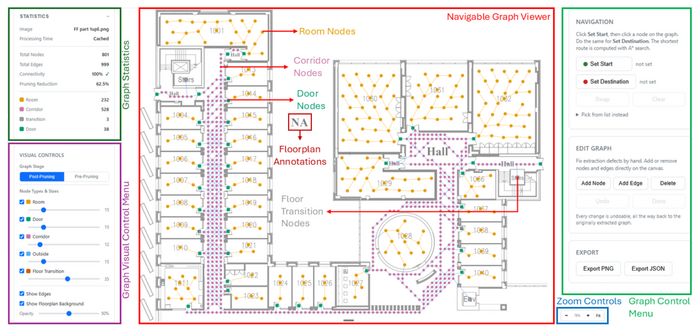
 

Tesseract: Interactive Conversion of Building Floor Plans into Multi-Floor Navigable Graphs [Demo]

Yaqoob Ansari, Eduardo Feo-Flushing, Khaled Harras
To appear in Proceedings of the 34th ACM International Conference on Advances in Geographic Information Systems (SIGSPATIAL), 2026
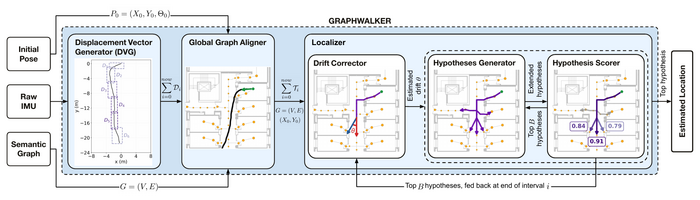
 

GraphWalker: Deployable Inertial-Based Indoor Localization via Trajectory to Graph Alignment

Mai Al-Mashhadani, Yaqoob Ansari, Khaled Harras, Eduardo Feo-Flushing
To appear in Proceedings of the 34th ACM International Conference on Advances in Geographic Information Systems (SIGSPATIAL), 2026
 

Towards Practical and Deployable Infrastructure-Free Indoor Localization

Mai Al-Mashhadani, Yaqoob Ansari, Eduardo Feo-Flushing, Khaled Harras
Proceedings of IEEE International Conference on Pervasive Computing and Communications Workshops (PerCom Workshops), 2026
PDF
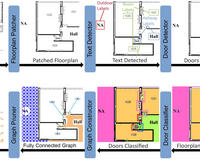
 

Tesseract: Unfolding Navigable Graph Representations from Low-Semantic Floor Plans

Yaqoob Ansari, Ammar Karkour, Eduardo Feo-Flushing, Khaled A. Harras
Proceedings of the 33rd ACM International Conference on Advances in Geographic Information Systems (SIGSPATIAL/GIS), 2025
PDF